Robust robot localization
WRAP: Wasserstein-Robust Adaptive Plug-in for Robot Localization
Submitted to IEEE RA-L
Overview
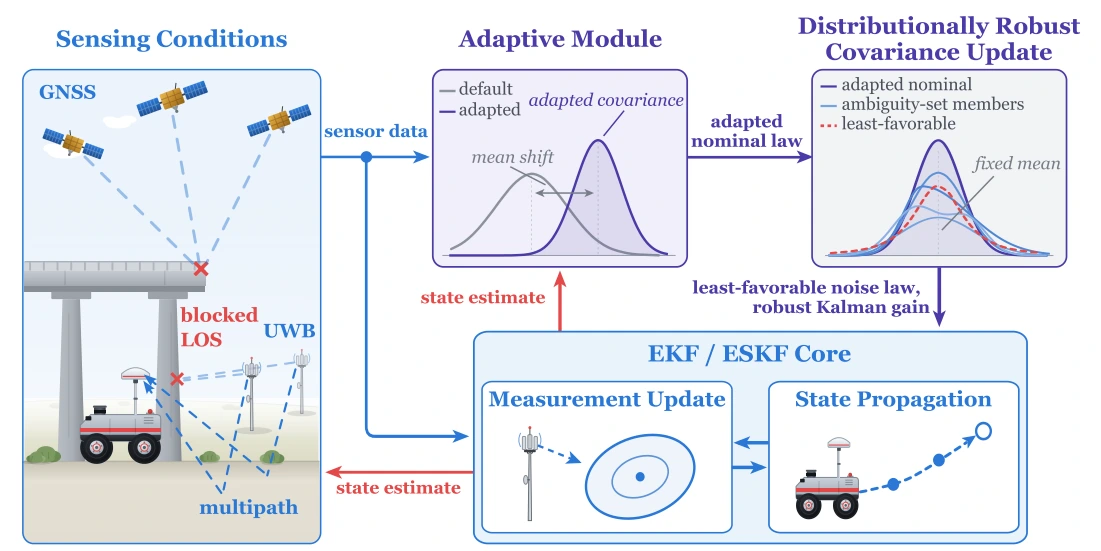
Robot localization becomes less reliable when sensing conditions change: GNSS can suffer from multipath, UWB links can become non-line-of-sight, and nominal noise models can become inaccurate.
WRAP adds an adaptive, Wasserstein-robust update to existing extended Kalman filter and error-state Kalman filter pipelines. An adaptive module supplies effective noise statistics; a robust local update accounts for remaining covariance uncertainty. The baseline propagation model, residual, and state representation remain intact.
Evaluation
The paper evaluates UWB–IMU localization on held-out sequences, studies GNSS–INS behavior, and reports embedded runtime on a Jetson Orin Nano. See the linked preprint for the experimental setup, results, and limitations.