Submitted to IEEE ICRA 2027
Autonomous aerial refueling
Learned visual keypoints, EKF sensor fusion, and uncertainty-aware MPC for probe-and-drogue docking.
- Robotics
- Planning & Control
- Learning-Based Methods
- State Estimation
My research is in robotics, with a focus on robust state estimation, learning-based control, and safe motion planning. I work with Prof. Naira Hovakimyan at the Advanced Controls Research Laboratory.
Ph.D. student, Mechanical Science & Engineering · 2025–present GPA: 4.0 / 4.0
B.S., Artificial Intelligence & Mechanical Engineering · 2025 GPA: 3.99 / 4.0
College of Engineering Outstanding Graduate Award
Outstanding B.S. Thesis Presentation Award
Research papers, robot systems, and experiments.
17 projects
Projects can appear in more than one topic.
Submitted to IEEE ICRA 2027
Learned visual keypoints, EKF sensor fusion, and uncertainty-aware MPC for probe-and-drogue docking.
Submitted to IEEE ICRA 2027
Conditional flow matching with control-barrier safety checks to discover new actions in unfamiliar environments.
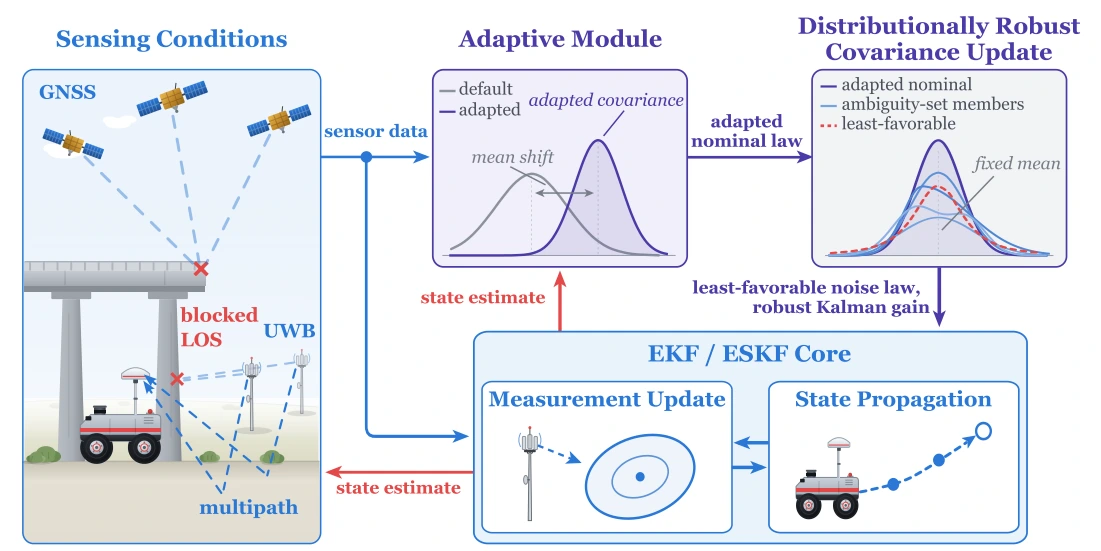
Submitted to IEEE RA-L
Adaptive noise models, including learned adapters, with Wasserstein-robust EKF/ESKF updates.
IEEE Conference on Decision and Control (CDC), 2026
A robust extended Kalman filter that accounts for noise mismatch and linearization error.
Autonomous vehicles
YOLO perception, motion planning, and control deployed on a full-scale Polaris GEM e4.
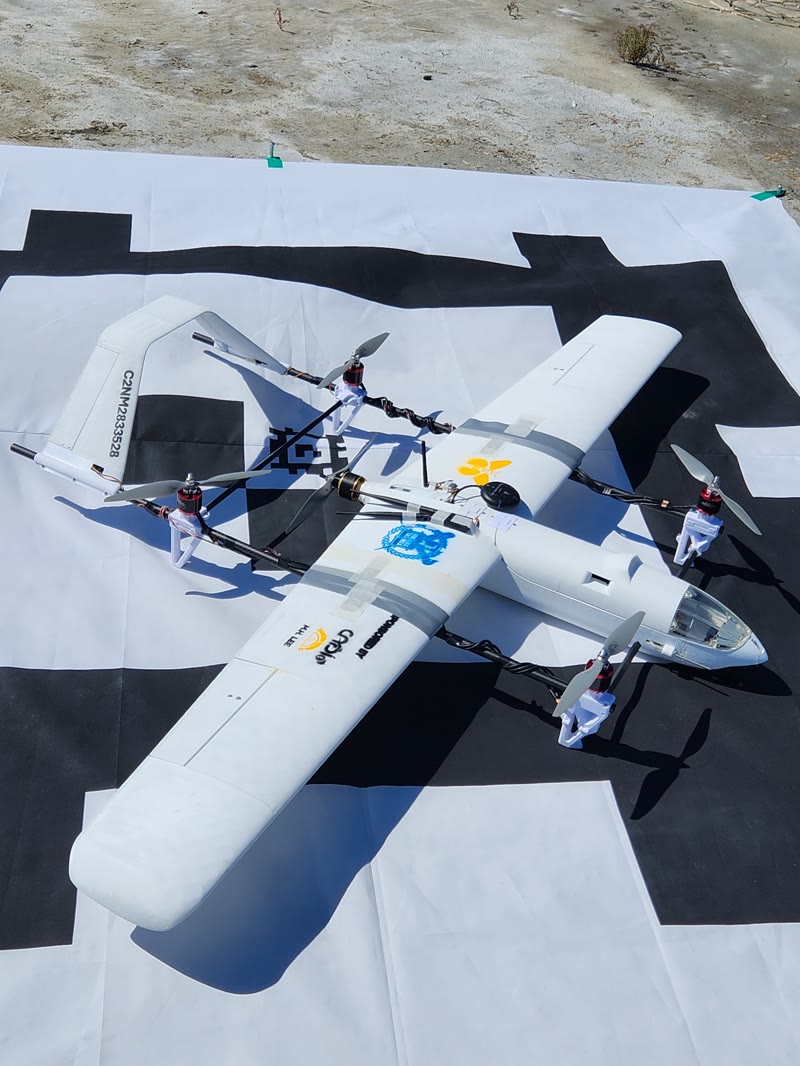
Grand Award · 2024
Led a 25-member team in VTOL design and flight testing; first place among 39 teams.
Robotic mechanisms
A length-adjustable mechanism, prototyped and tested on a flying quadrotor.
Sampling-based control
Automatic inverse-temperature tuning for model predictive path integral control.
AIAA Design / Build / Fly
Landing control for a glider launched from a mothership at 100 m altitude.
Aircraft development
Building and testing a quadplane through hover and transition flight.
Model predictive control
Combining disturbance observers and MPC to account for unmodeled quadrotor dynamics.
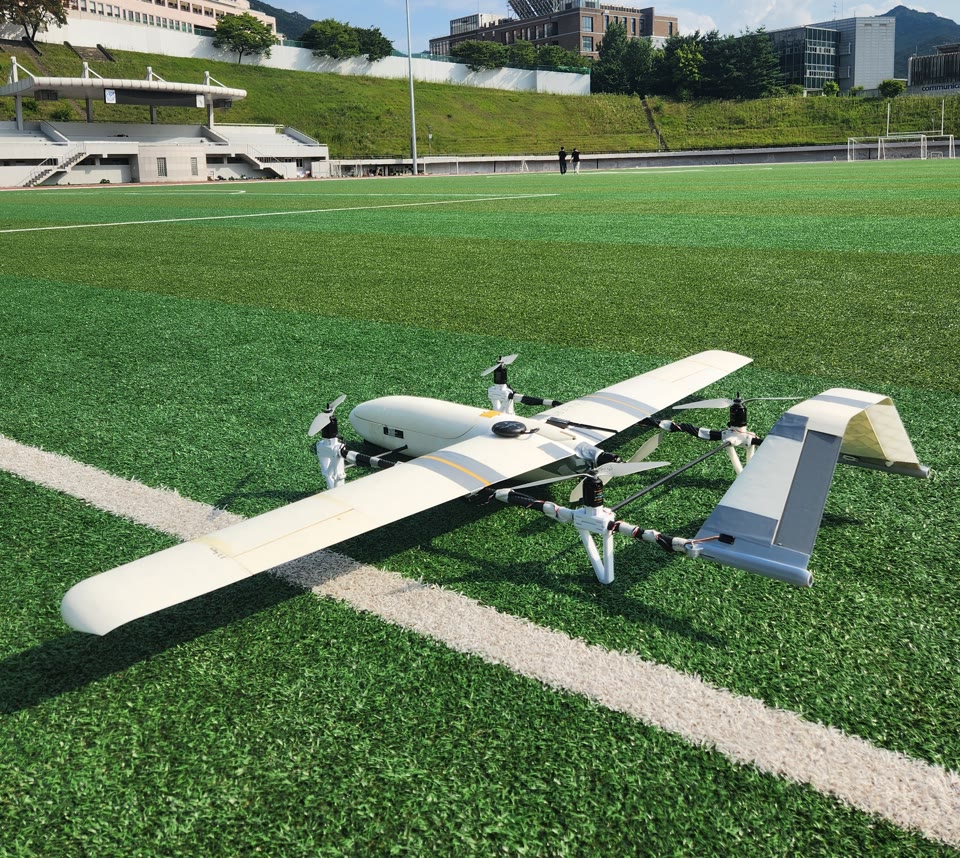
Aircraft development
Design, integration, and autonomous flight testing with Team Bulnabi.
Teaching & hardware
Hands-on seminars covering assembly, calibration, flight experiments, and log analysis.
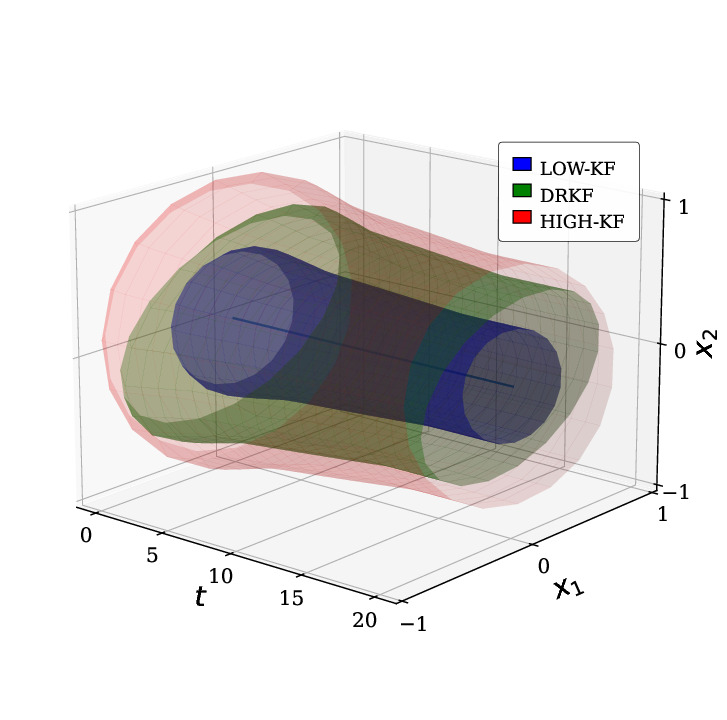
Preprint
Noise-centric Wasserstein ambiguity sets for robust filtering under uncertain process and measurement noise.
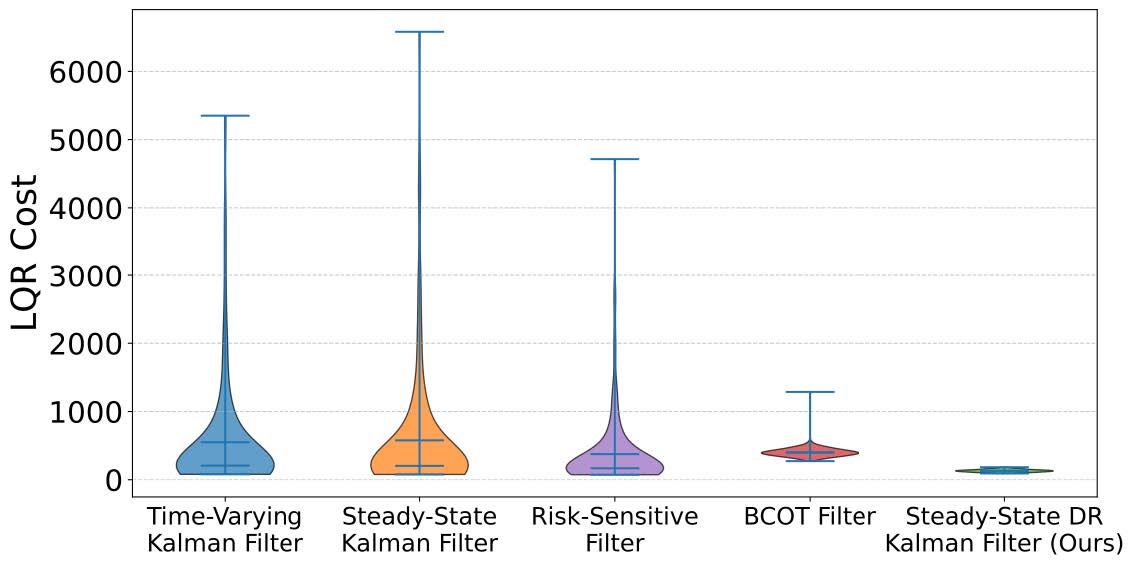
IEEE Conference on Decision and Control (CDC), 2025
A constant-gain robust estimator obtained from a single offline optimization, with convergence guarantees.
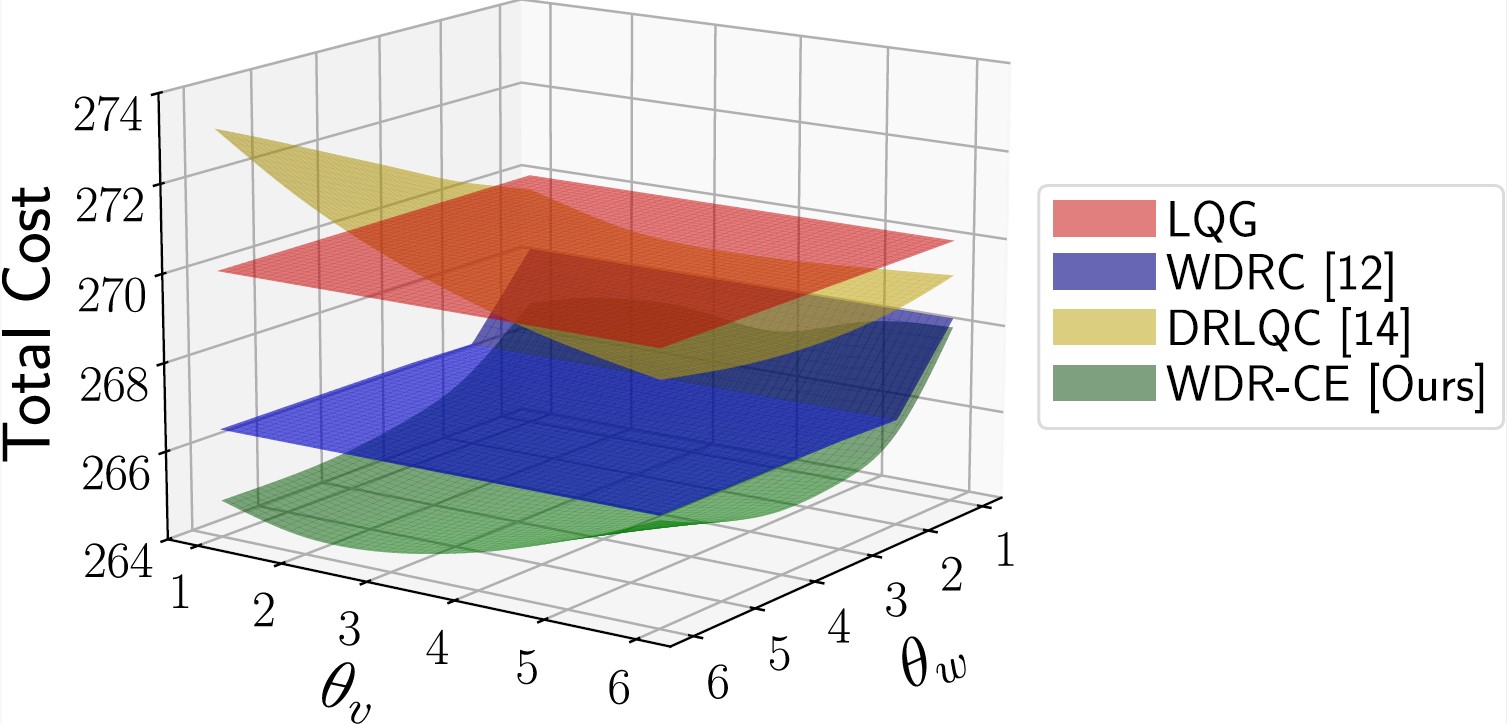
Preprint
Joint control and Kalman filtering for partially observed systems with uncertain disturbance and measurement distributions.
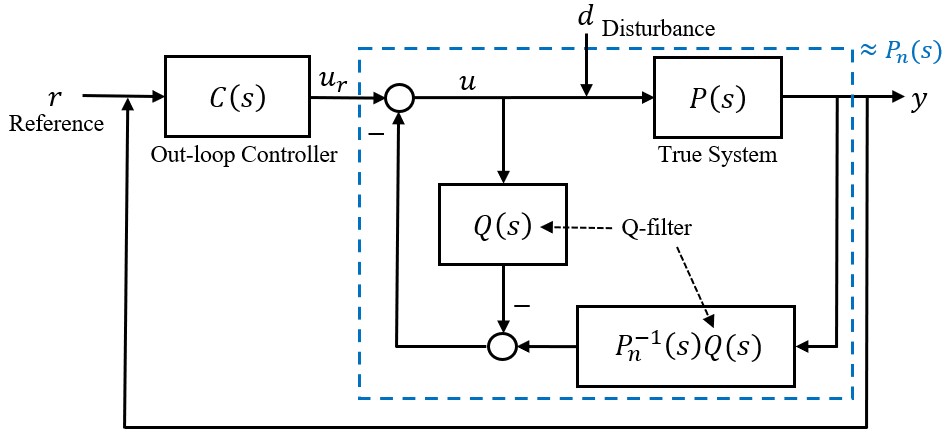
Institute of Control, Robotics and Systems (ICROS), 2024
Stability conditions when a disturbance observer's nominal model and the true system have different orders.
Submitted to IEEE ICRA 2027
Submitted to IEEE ICRA 2027
Submitted to IEEE RA-L
IEEE Conference on Decision and Control (CDC), 2026
IEEE Conference on Decision and Control (CDC), 2025
Institute of Control, Robotics and Systems (ICROS), 2024
* Equal contribution
Research Assistant · UIUC
Research Intern · Seoul National University
Aerospace Engineering Intern · GNC Team
Teaching Assistant · UIUC
IEEE Transactions on Signal Processing
IEEE Transactions on Control of Network Systems
Team Leader · Quadrotor build/fly seminars
Korea Robot Aircraft Competition · Grand Award, 2024