Engineering & robotics
Automated Inverse Temperature Tuning Algorithm for MPPI Control
Project Duration : SEP ‘23 - JUN ‘24
Outstanding B.S. Thesis Presentation Award, Department of Mechanical Engineering, Seoul National University, 2024.
(Last update : 2024-06-24)
This project implements automatic inverse-temperature tuning for MPPI in MuJoCo MPC, with quadrotor hovering and path-tracking experiments.
Model Predictive Path Integral(MPPI)
MPPI samples candidate control sequences, evaluates their rollout costs, and combines them using cost-based weights. It supports non-differentiable costs and parallel rollout evaluation. Reference
Inverse Temperature Tuning
The parameter $\lambda$ (inverse temperature) affects control cost and state fluctuation. This project updates $\lambda$ alongside the MPPI controller to reduce state fluctuations while maintaining low cost.
In the quadrotor experiments, $\lambda$ converged from different initial values, and adaptive tuning reduced fluctuations in hovering and path tracking.
Experimental Results
Position tracking under different fixed values of $\lambda$:
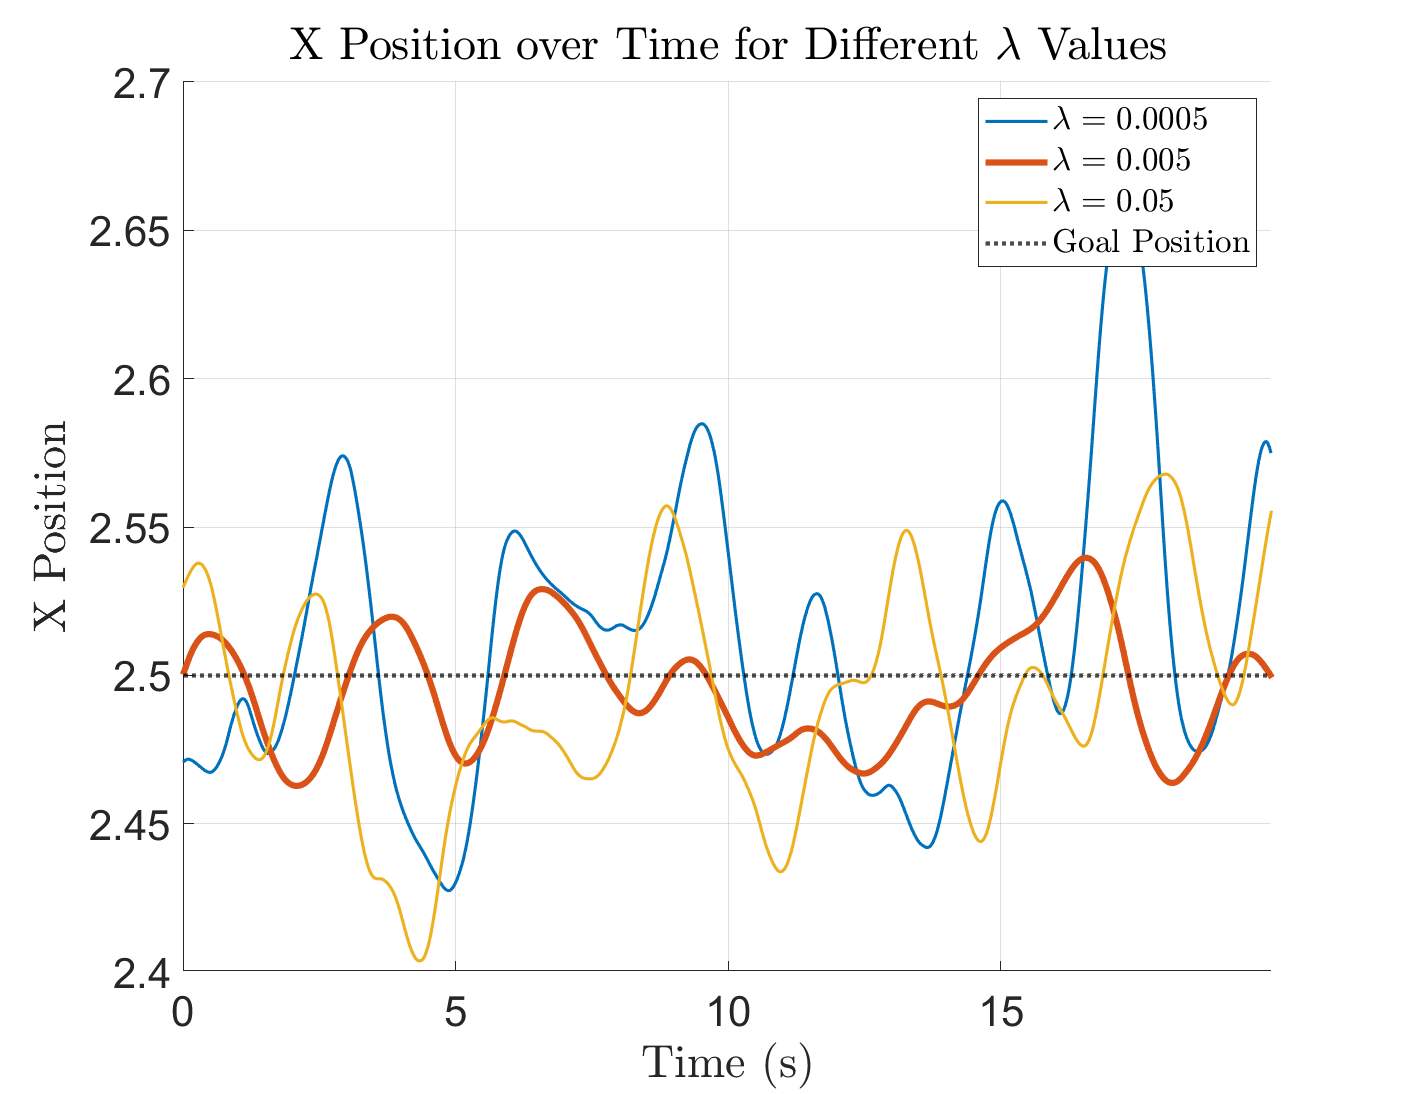
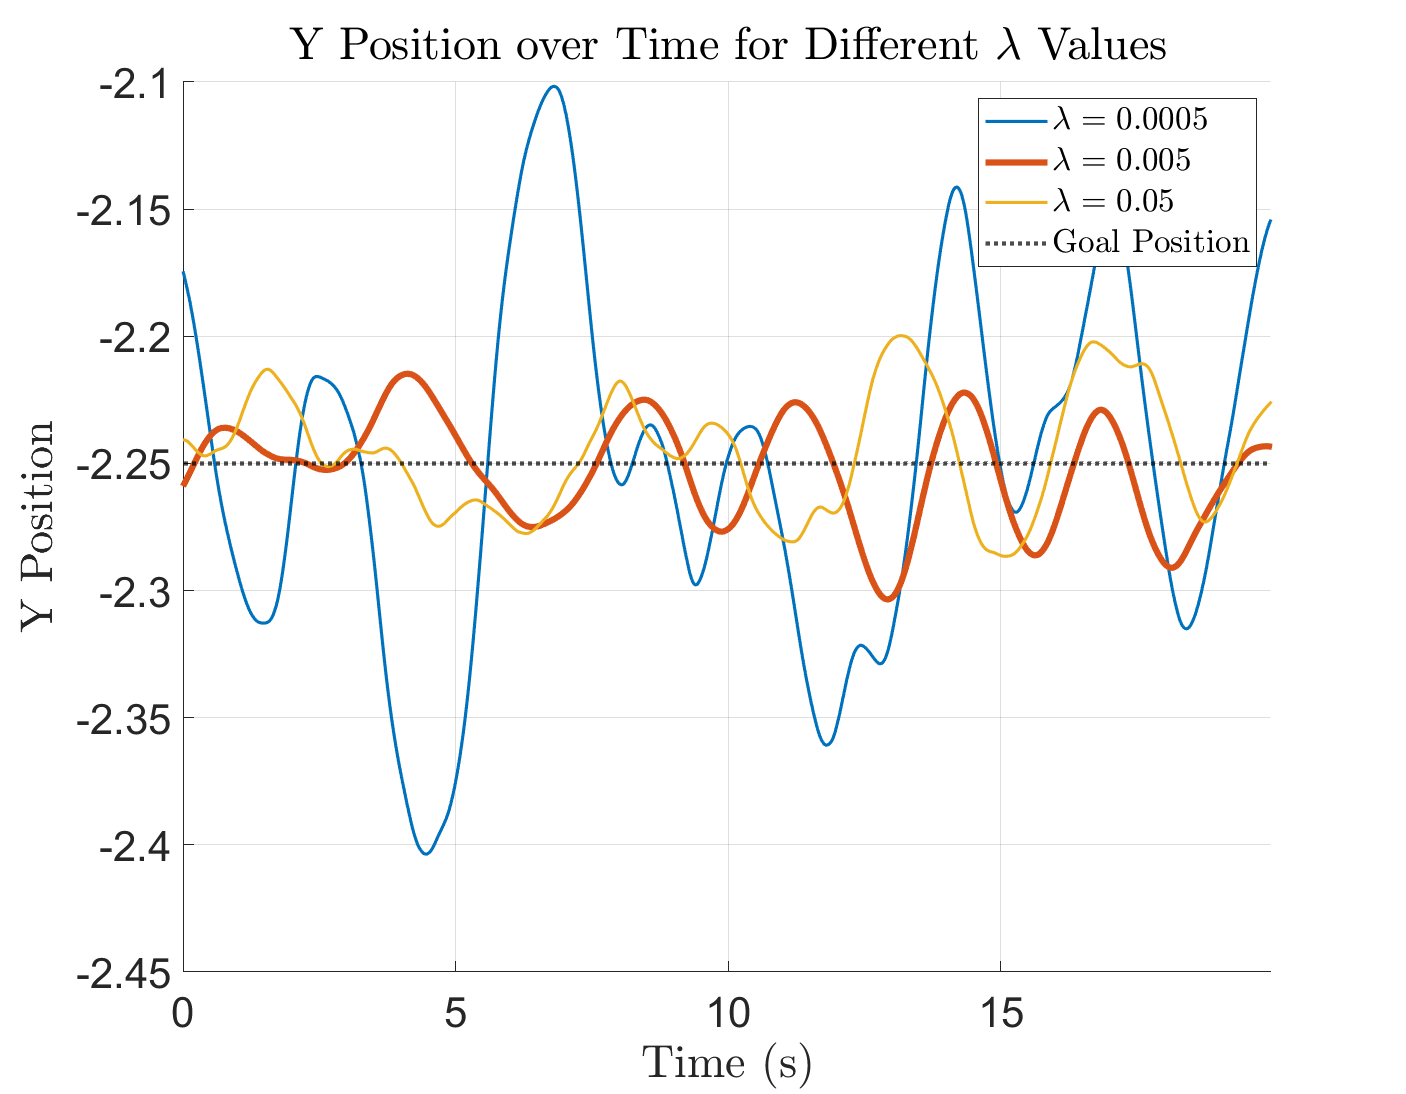
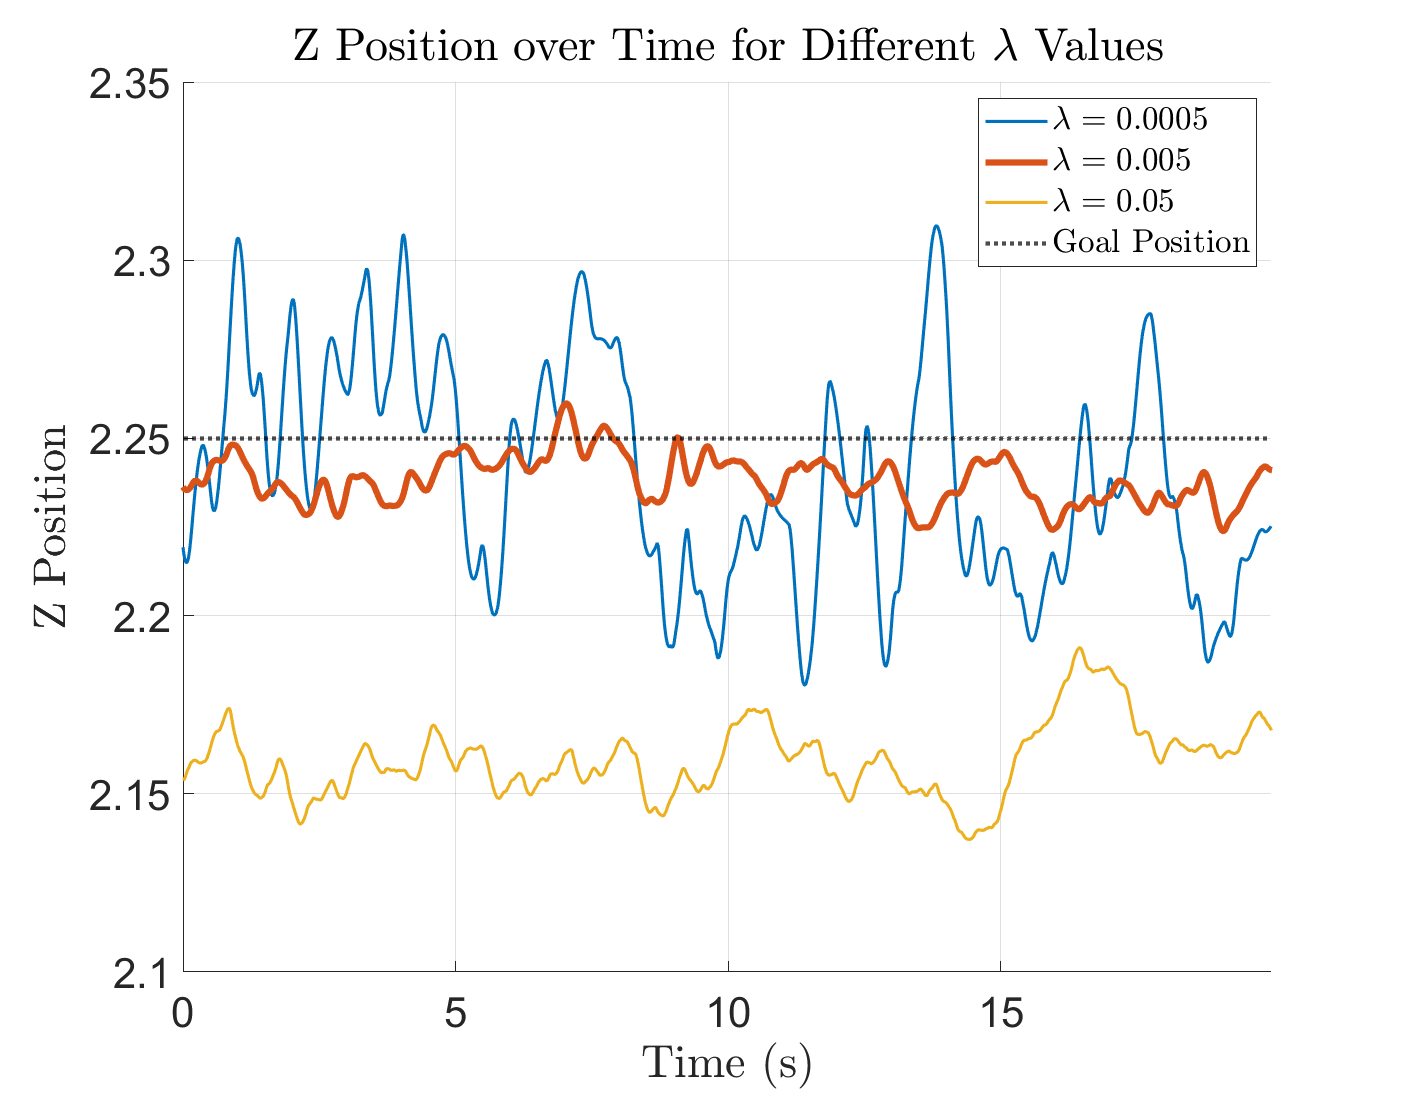
The above figures demonstrates the importance of selecting proper $\lambda$. ($\lambda=0.005$ shows small cost with small fluctuation in this case.)
Online updates from different initial values of $\lambda$:
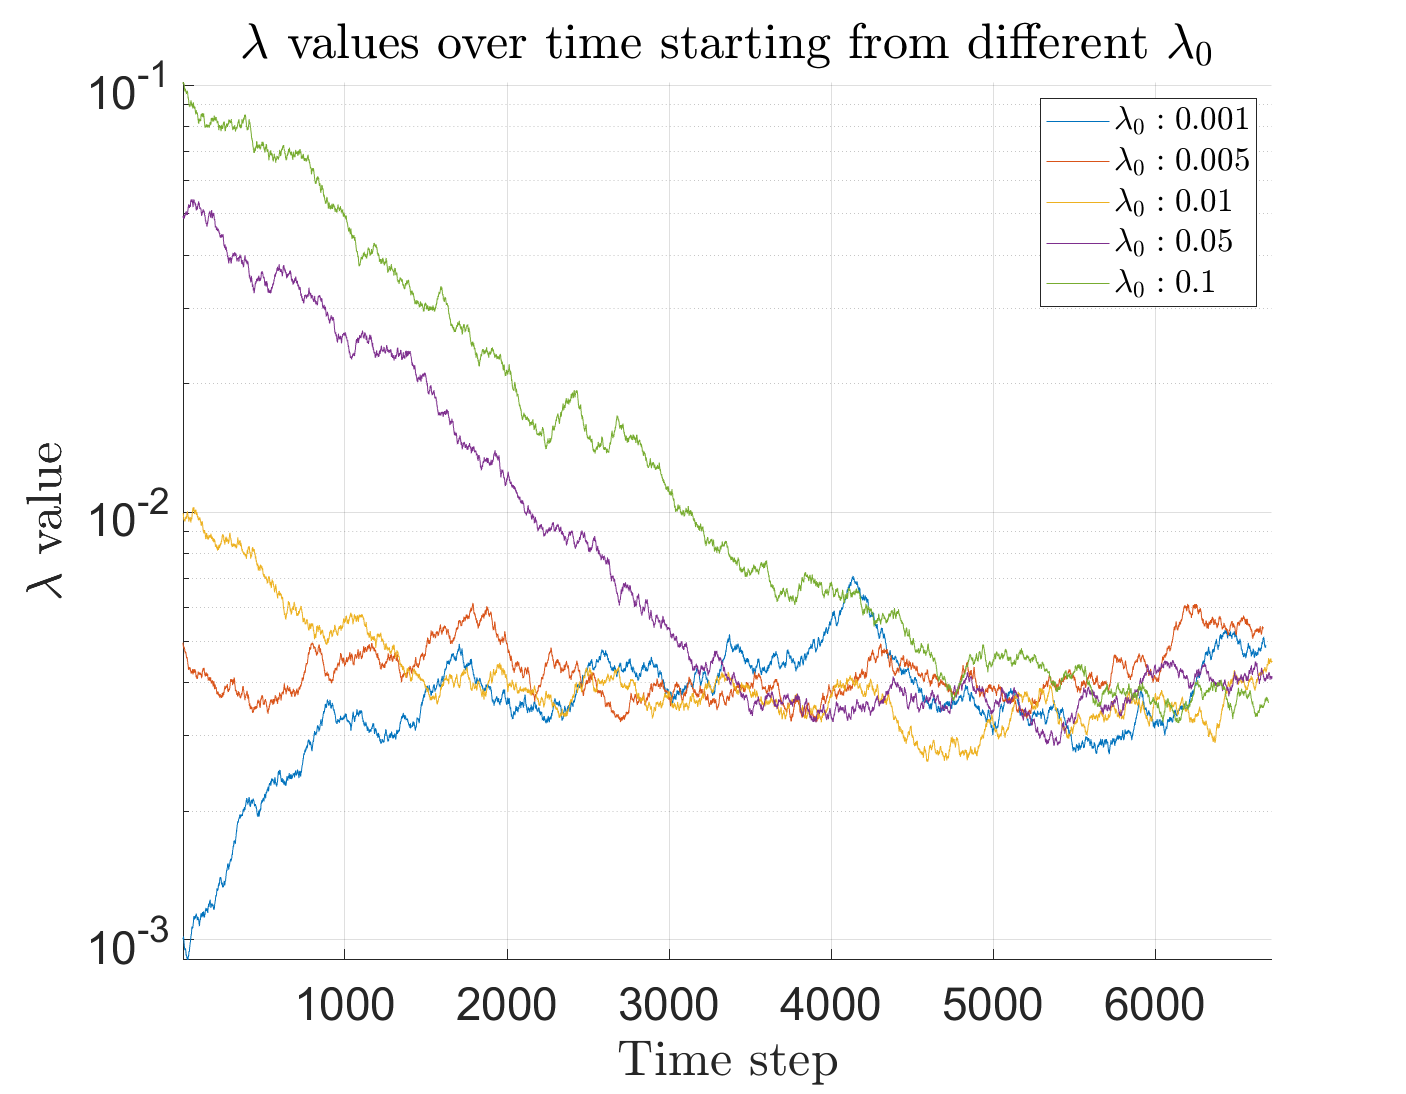
$\lambda$ starting from different initial condition converges.
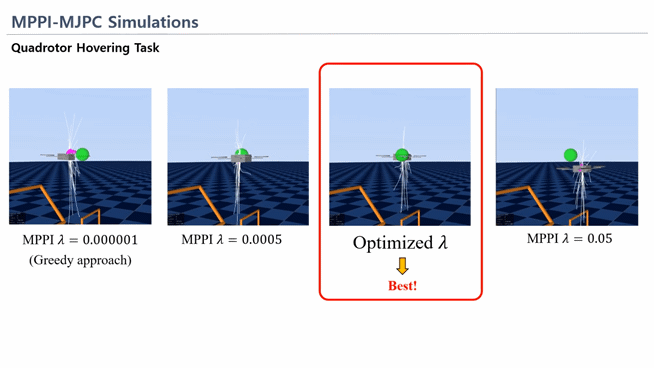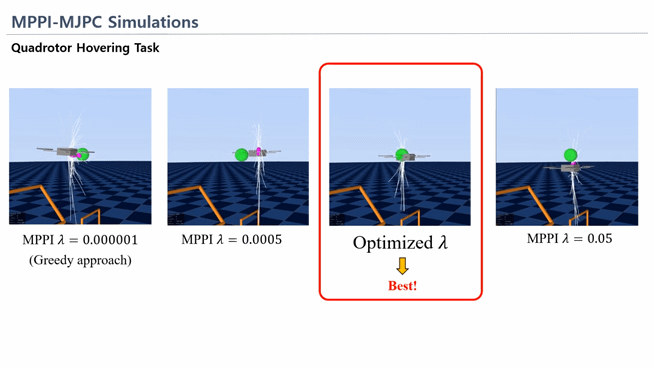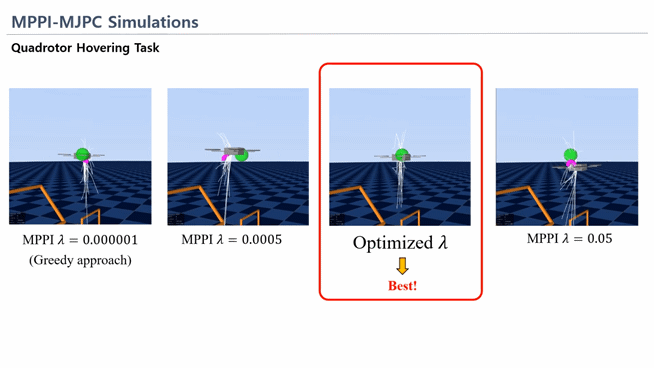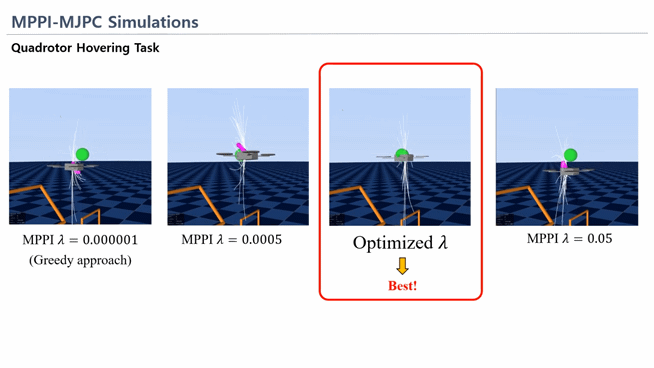
The results from MPPI with the properly tuned $\lambda$ showed reduced fluctuations compared to different selections of $\lambda$. Additionally, the optimal $\lambda$ values consistently converged to a specific range despite different initial values, underscoring the effectiveness of our approach.